Selected work
Robots built from mechanics to control.
Six research projects spanning high-payload climbing, dexterous and dynamic manipulation, real-time perception, model predictive control, and multi-robot systems.
Six selected projects
Research
Robot hardware, control, perception, and learning.
ICRA 2026
2023–present
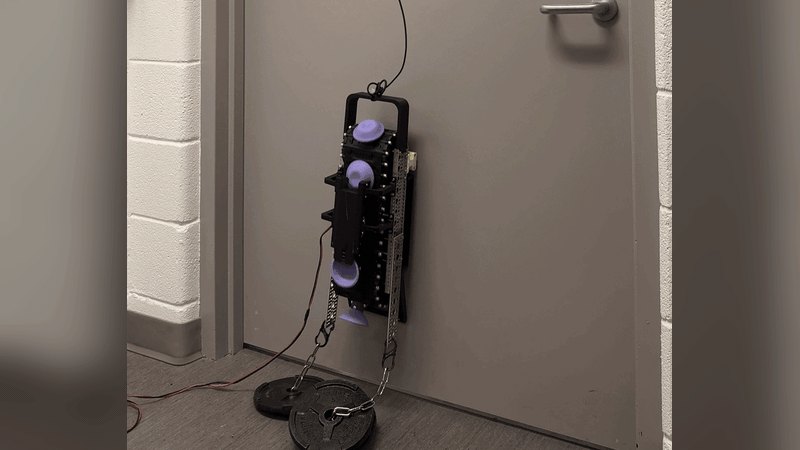
High-payload wall climbing
Mechanical design · Control
Passive suction enables an 8 kg payload on plaster and glass.
My role Mechanism design & payload testing
Project details +
FREE Lab · University of Michigan
Problem
Carry payloads on vertical surfaces using passive bistable suction cups.
My contribution
I designed the passive bistable-suction wall-climbing robot and evaluated its payload capability on plaster and glass.
Result
Demonstrated an 8 kg payload on plaster and glass; first-author ICRA 2026 paper and a 2025 U.S. provisional patent application.
ICRA 2027 submission
May–Aug. 2026
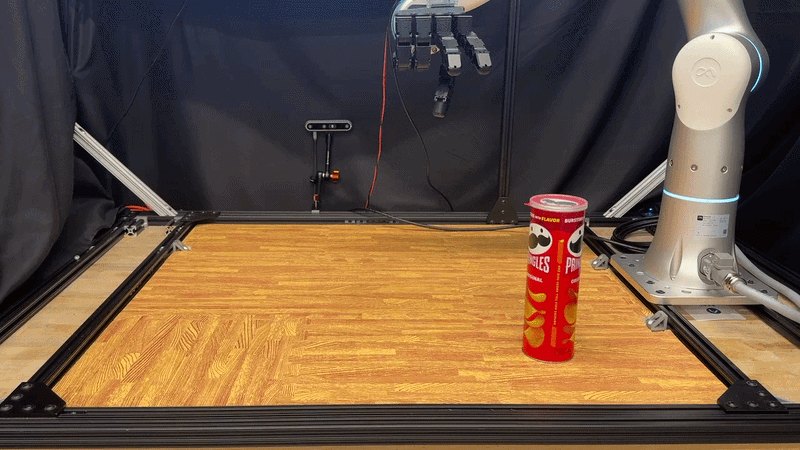
Steerable & reactive grasping
Manipulation · Learning
Modular three-finger grasping with reactive reaching and tactile feedback.
My role Grasping framework & hardware validation
Project details +
Biomimetic Robotics Lab · MIT
Problem
Connect object geometry, reactive reaching, and tactile feedback in a modular grasping framework.
My contribution
I developed the three-finger grasping framework, combining geometry-based affordances, reactive reaching, and tactile/proprioceptive reinforcement learning, and demonstrated it on hardware.
Result
Hardware demonstrations on seen and unseen objects; released as a first-author arXiv preprint and submitted to ICRA 2027.
Ongoing research
May–Aug. 2026
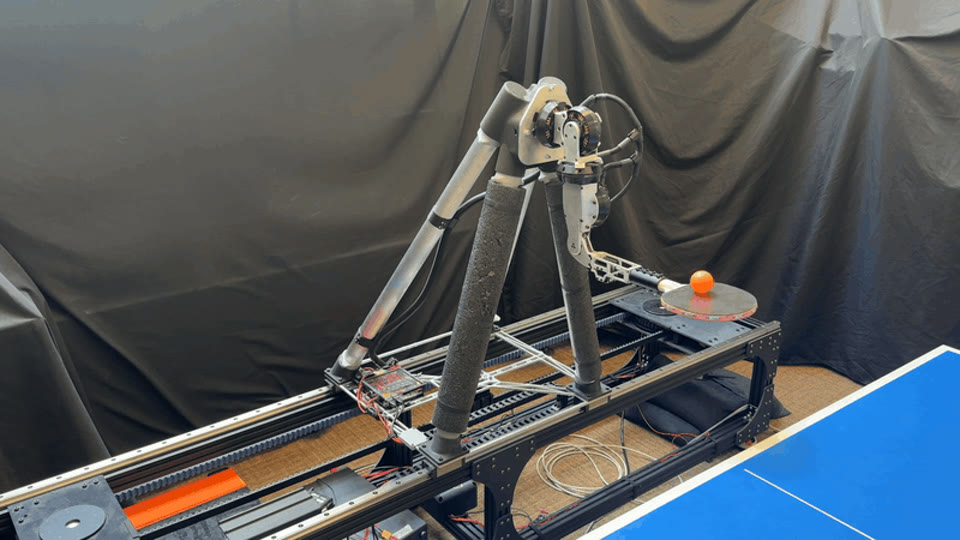
MIT Table Tennis Robot V2
Perception · Control · Learning
A custom 220 Hz perception stack for MIT's second-generation table-tennis robot.
My role Real-time perception & system integration
Project details +
Biomimetic Robotics Lab · MIT
Problem
Give a high-speed table-tennis robot reliable ball state estimates and connect them to learning- and model-based controllers.
My contribution
I implemented 220 Hz YOLO-based ball localization and integrated it with the hardware system, assisting with MPC controller deployment and testing for the robot's table-tennis skills.
Result
Integrated real-time ball localization with the robot's control stack for hardware testing across dynamic table-tennis skills.
Science Robotics 2026
May–Aug. 2024 & 2025
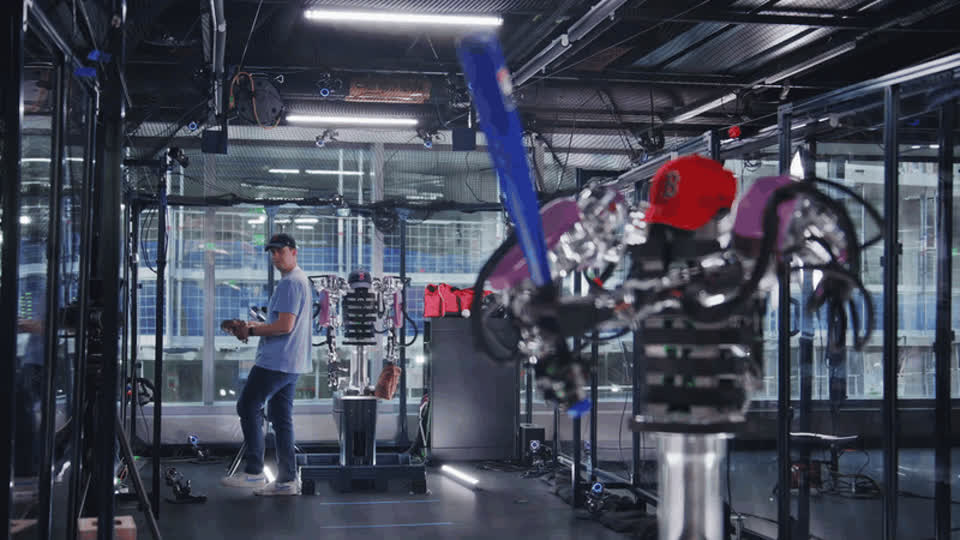
AthenaZero
Dynamic manipulation · Robot hardware
Low-inertia bimanual hardware for throwing, catching, and batting at human-comparable speeds.
My role Hardware intern · actuator testing & assembly (not a paper author)
Project details +
RAI Institute · formerly Boston Dynamics AI Institute
Problem
Build a bimanual manipulator with low effective inertia and high control authority for fast, contact-rich tasks at human-comparable timescales.
My contribution
Across two summer internships, I built an automated Python motor-dynamometer test suite, characterized actuator friction and torque–velocity behavior, designed a 1-DOF camera mount, and assembled 40 quasi-direct-drive actuators using custom test fixtures.
Result
The resulting platform achieved a human-comparable effective endpoint mass and demonstrated throwing above 30 m/s, with catching and batting above 14 m/s.
Research project
2026
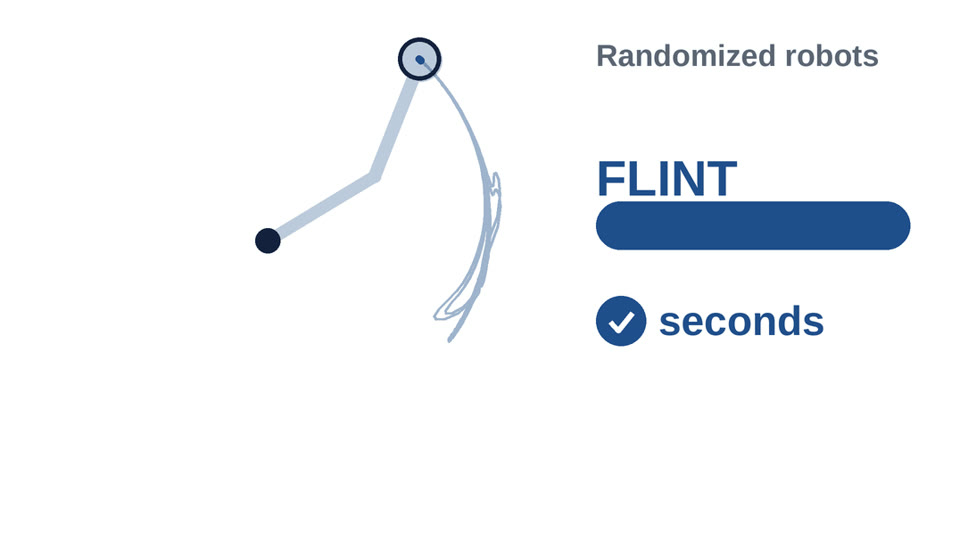
FLINT feedback control
Model predictive control · Simulation
MPC-based feedback control for randomized robot models.
My role MPC feedback control & simulation
Project details +
University of Michigan
Problem
Track optimized motions when robot geometry and dynamics vary between systems.
My contribution
I developed and evaluated the MPC feedback-controller workflow in FLINT, using randomized robot models to test closed-loop trajectory tracking across changing mechanisms.
Result
Demonstrated feedback-control rollouts across randomized two-link robot models in simulation.
Research project
Coordinating fixed-wing UAV formations
Simulation · Control
Simulation and control for interconnected fixed-wing formations.
My role Simulation & formation controllers
Project details +
FREE Lab · University of Michigan
Problem
Simulate and coordinate interconnected fixed-wing aircraft in formation.
My contribution
I developed the simulation and control stack for interconnected fixed-wing UAV formations.
Result
Implemented Circle/Flying-V and waypoint-following controllers in the simulation and control stack.
Additional work
Engineering projects
Hands-on systems and competition robotics.
Design project
Jan.–Apr. 2025
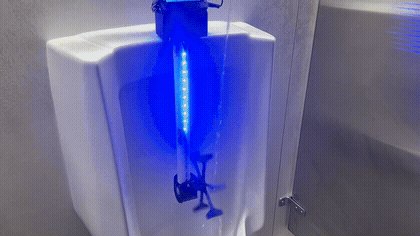
P-Wheel: fluid-powered flow sensing
Design · Embedded systems
Fluid-driven flow sensing with real-time LED and LCD feedback.
My role Mechanism, sensing & embedded feedback
Project details +
University of Michigan
Problem
Measure stream velocity without pumps or wall power and provide interactive feedback.
My contribution
I designed the fluid-driven paddle wheel and encoder sensing system, and built an LED and LCD feedback loop that gamifies aim against cohort high scores.
Result
Our team ranked first in the cohort and was one of four selected to pitch to venture capitalists.
Competition robotics
2012–2023
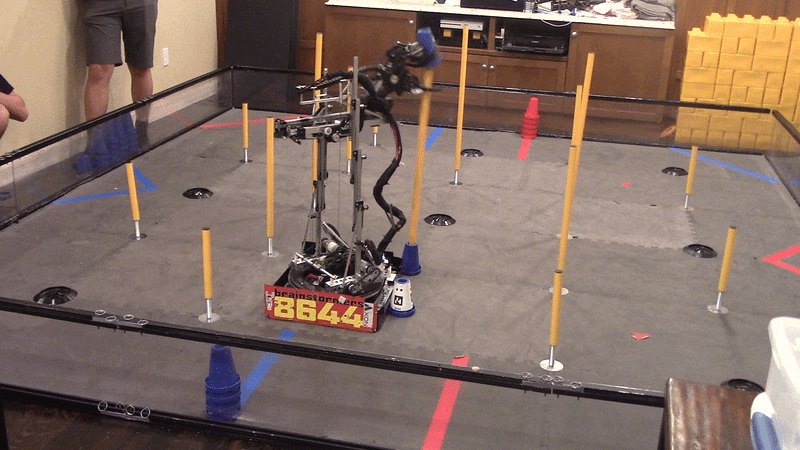
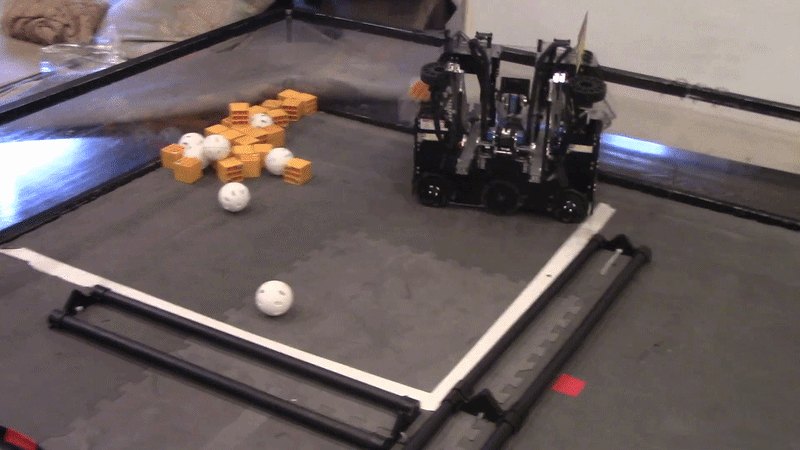
Competition robotics
Robot design · Software · Leadership
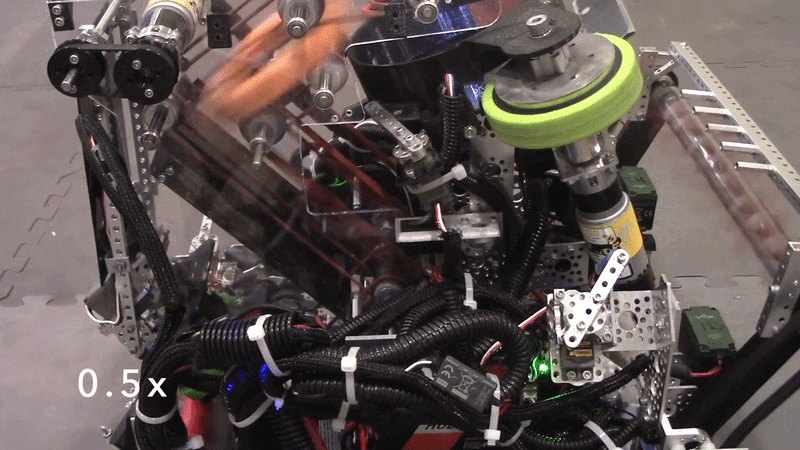
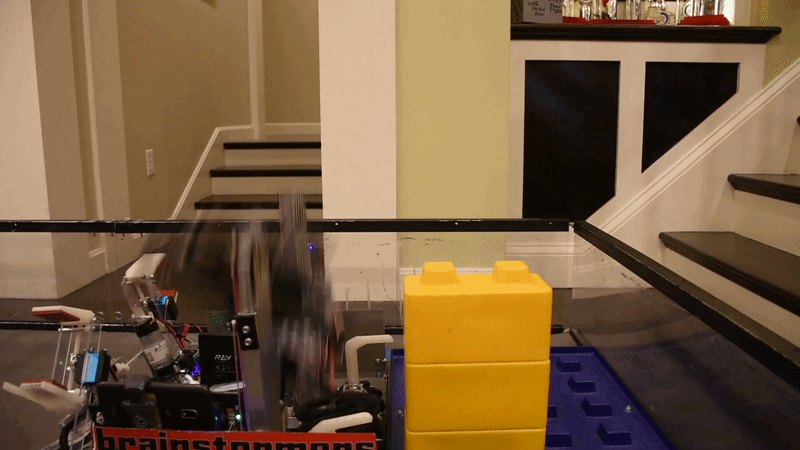
Competition robots built through years of design, software, and testing.
My role Team captain · Robot design · Software
Project details +
The Brainstormers
Problem
Design, program, and refine competition robots while leading a team.
My contribution
As team captain, head robot designer, and software lead for The Brainstormers, I led robot design and software and mentored more than 100 teams.
Result
Team highlights include a 2022 World Championship finalist finish, six state championships, and a 2023 World Championship Innovate Award second-place finish.
2023 season
Chesapeake Winning Alliance Captain · World Championship Innovate Award, 2nd place · Asia Pacific Open Winning Alliance
Watch video2022 season
Arkansas Winning Alliance Captain & Inspire Award · World Championship Finalist Alliance · World Championship Control Award Finalist
Watch video2021 season
Massachusetts Top Ranked & Design Award, 2nd place · Vermont Top Ranked & Control Award
Watch video2020 season
Massachusetts Winning Alliance Captain · Vermont Motivate Award
Watch video